Swapneel Wagholikar

I am a computer vision engineer with three and a half years of experience building perception and imaging systems that have to run on real hardware. I work across both halves of the field — classical geometric vision like camera calibration, multi-view geometry and visual-inertial estimation, and deep learning for detection, segmentation and depth — and I am most useful where the two meet a power budget. The sensors I have worked with ranged from LiDAR and IMUs to visible cameras, uncooled LWIR microbolometers, broadband SWIR/MWIR cameras, and long-range optics with very narrow fields of view.

Since December 2024 I have been at Pixels On Target, LLC in Sunrise, FL, working on infrared imaging: ISP design, sensor calibration and image quality, alongside airborne perception and geospatial segmentation.

Before that I earned my M.S. in Robotics Engineering at Worcester Polytechnic Institute, where I researched point-cloud completion at VISLab under Prof. Ziming Zhang. Along the way I built depth completion and LiDAR-camera fusion at DEKA Research & Development, retrieval-augmented LLM tooling at Findability Sciences, GPS-IMU odometry at Void Robotics, and monocular depth on edge hardware at Onki AI.

I like problems where the sensor is challenging to work with, the compute is limited, and the answer still has to be right. Feel free to reach out — wagholikarsd@gmail.com.
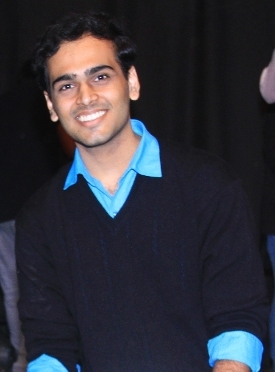
Portrait of Swapneel Wagholikar

What I work on

Deep Learning & Perception

Training and adapting models on real sensor data, and the dataset and label work that decides whether they hold up.

  • Object detection
  • Semantic segmentation
  • Depth estimation & completion
  • Training pipelines
  • Label audit
  • PyTorch

Geometric Computer Vision

The classical half — recovering pose, structure and orientation from images when there is no model to train.

  • Camera calibration
  • Multi-view geometry
  • Structure from motion
  • Visual-inertial odometry
  • ICP
  • Quaternions & boresight

Camera, ISP & Image Quality

ISP blocks written from scratch for infrared bands, and the calibration and noise work behind them.

  • AEC
  • Tone mapping
  • Autofocus
  • NVESD 3D noise
  • Two-point NUC
  • Denoising

Edge Deployment & Autonomy

Getting models inside the latency, memory and power budget of the hardware that actually ships, and the systems around them.

  • TensorRT
  • INT8 quantization
  • Pruning
  • Jetson
  • FPGA fixed-point
  • ROS2 / PX4 / MAVLink

Experience

Pixels On Target, LLC

Computer Vision Engineer

Sunrise, FL
Dec 2024 – Present

Defense and public-safety imaging systems. Described at the level of method and problem class; program details omitted.

Airborne perception and system integration

  • Co-designed an embedded airborne imaging system — compute and sensor selection, and the interfaces carrying commands, telemetry and video — then trained the object detection model that runs on it, deployed as a TensorRT engine on NVIDIA Jetson with detections geo-located against terrain elevation data.

Infrared calibration and image quality

  • Own the production calibration automation for uncooled LWIR camera cores, and characterized focal-plane noise with the NVESD 3D noise model to decide which denoising blocks — destriping, spatial and temporal denoise, flare correction — were worth writing.

ISP block design

  • Designed the auto-exposure, histogram tone mapping and autofocus blocks for a broadband SWIR/MWIR camera from scratch, then wrote the bit-accurate fixed-point golden reference model the FPGA team verified their RTL against.

Pointing, orientation and visual-inertial estimation

  • Rewrote the celestial calibration math behind a heading reference, and built a drift-free orientation reference by calibrating pan-tilt encoders against an IMU through quaternion mappings, boresighted onto the optical axis.

Geospatial segmentation and route planning

  • Built satellite-imagery semantic segmentation end to end and the 2.5D route planner on top of it, argued that planner onto a classical algorithm for lack of training data, and ported it to C++ for ATAK integration.

Onki AI

Machine Learning Engineering Intern

New York, NY (remote)
Sep 2024 – Dec 2024

Monocular depth on edge hardware

  • Built monocular depth estimation for a mobile vending robot with a MiDaS-family model, optimized with TensorRT for real-time inference on a Jetson Nano.

DEKA Research & Development

Perception Software Intern

Manchester, NH
Sep 2023 – Apr 2024

LiDAR-camera fusion and calibration

  • Wrote a C++/ROS pipeline that synchronises a Velodyne solid-state LiDAR with an Intel RealSense stereo camera inside a 50 ms window, projecting the two into LiDAR-backed ground-truth depth maps, with auto-calibration recovering the extrinsics so no manual alignment pass was needed.

Depth completion and edge deployment

  • Built a depth-completion pipeline on CompletionFormer that turns sparse LiDAR returns into dense depth — fine-tuning and synthetic augmentation cut RMSE 81% and MAE 92% against the pretrained model — then quantized it to INT8 for edge deployment.

Findability Sciences

Data Science Graduate Researcher (GenAI/LLM)

Boston, MA (remote)
Jan 2024 – May 2024

Retrieval-augmented LLM interface

  • Built an LLM interface that lets business users query and visualise economic records, using retrieval-augmented generation over OpenHermes-2.5 and the vector store behind it.

Economic forecasting

  • Ran rolling-window forecasts across 50 years of 118 economic indicators with LSTM and VARIMA models, reaching 0.04 MAPE, and estimated recession probability with a support vector machine over the same set.

Void Robotics

Robotics Software Intern (Perception, Controls)

Marathon, FL (remote)
May 2023 – Aug 2023

GPS, visual and inertial odometry

  • Fused RTK-GPS, a ZED2 stereo camera and an IMU into an odometry module holding position within a centimetre in motion, under open sky with an RTK fix.

SLAM packaging

  • Packaged an error-state Kalman filter for SLAM as a Dockerised ROS2 node.

Vision, Intelligence and Systems Lab, WPI

CV/ML Graduate Researcher

Worcester, MA
May 2023 – Aug 2023

Transformer point-cloud completion

  • Trained and extended PointAttN, a transformer for point-cloud completion under Prof. Ziming Zhang, adding a hyper-spherical module after the encoder that improved chamfer distance 33% over the published baseline to 0.0929 mm.

Atlas Copco (GECIA)

Design Engineer

Pune, India
Nov 2020 – Jul 2022

Mechanical design and documentation

  • Produced technical packages for oil-free compressor designs covering 3D models, P&ID and bill of materials, reviewed designs through the internal audit process, and mentored junior engineers on design standards.

Projects

Graduate and personal work, each with source on GitHub.

Embedded Deep Learning

Pruned a VGG16 classifier by 75% and quantized it to uint8; ran neural architecture search over the MCUNet super-network for microcontroller deployment; and cut inference cost with entropy-based early exit on BranchyNet.

Mobile NeLF

Deployed a neural light field model on an M1 device through Lens Studio and ONNX after knowledge distillation and pruning.

3D Semantic Segmentation

Built a LiDAR map with point-to-point ICP and transferred SegFormer's semantic labels onto it by point painting, on KITTI.
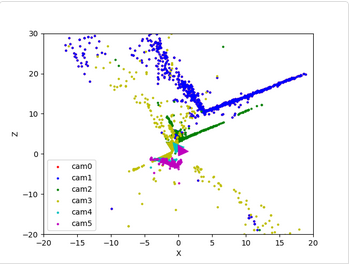
Sparse point cloud of a building facade reconstructed from several camera views, with camera frusta and epipolar rays

Structure from Motion

Reconstructed 3D scenes from stereo correspondences through non-linear triangulation, PnP and bundle adjustment.

Auto Calib

Implemented Zhang's camera calibration, recovering intrinsics and extrinsics by non-linear optimization.
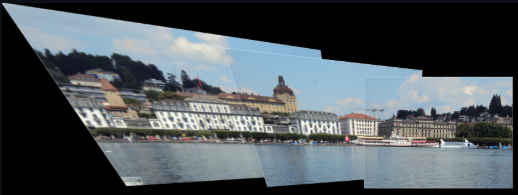
Panorama stitched from several overlapping photographs of a waterfront

Auto Pano

Stitched photo sets into panoramas using corner detection, ANMS, feature matching and RANSAC-estimated homographies.

Dynamic Navigation

Combined AIT* and BIT* global planning with MPC local control for a non-holonomic robot in dynamic environments, in ROS2 and Gazebo.

3D Trajectory Tracking

Designed a sliding-mode controller for micro-UAV 3D trajectory tracking in ROS and Gazebo.

Complex Highway Navigation

Compared DQN, DQN-MR and DQN-PER in OpenAI's highway-env, with prioritised experience replay coming out ahead.

Skills

Languages
Python, C++, C, CUDA, MATLAB, Bash
Computer Vision & Machine Learning
Object detection (YOLOv11, YOLOv4), semantic segmentation (SegFormer, satellite/SAR), depth estimation and completion (CompletionFormer), visual-inertial odometry, sensor fusion (LiDAR–camera, GPS–IMU), camera calibration (intrinsic, extrinsic, boresight), multi-view geometry, structure from motion, point clouds, ICP, Kalman filtering (EKF, ESKF), PyTorch, OpenCV, ONNX
Camera, ISP & Image Quality
ISP block design (AEC, AGC/tone mapping, autofocus, gamma), image quality tuning, dynamic range optimization, thermal imaging (LWIR uncooled microbolometer, FPA), broadband infrared (SWIR, MWIR), radiometric calibration, two-point NUC, 3D noise characterization (NVESD model), denoising (destriping, spatial, temporal, dithering, flare), shutterless correction and gain maps, ROIC parameter characterization, temperature-chamber and blackbody calibration, narrow-FOV multi-target calibration
Edge & Embedded
TensorRT, ONNX Runtime, quantization (INT8, uint8), pruning, knowledge distillation, neural architecture search, early-exit inference, NVIDIA Jetson (Orin NX, Nano), FPGA/SOM porting, fixed-point conversion, golden reference models, real-time latency and power budgeting, Docker
Robotics & Autonomy
ROS, ROS2, PX4, ArduPilot, MAVLink, gRPC/Protocol Buffers, GStreamer/RTSP, ATAK integration, path planning (AIT*, BIT*, RRT, 2.5D terrain routing), MPC, sliding-mode control, geospatial tooling (QGIS, GDAL, DTED, coordinate transforms), Gazebo, RViz
Tools
Linux, Git, CMake, pytest

Education

Worcester Polytechnic Institute

M.S. Robotics Engineering

Worcester, MA
Aug 2022 – May 2024

GPA 4.0/4.0. Coursework across computer vision, deep learning, reinforcement learning, motion planning and robot control.

Publications

  1. Analysis of 2D Auxetic Metamaterial as a Variable Macro and Micro Structural Filter. A. Shivdeo, A. Hardikar, R. Bhikule, S. Wagholikar, O. Borhade, M. V. Walame. IRJET, Vol. 6, 2019.
  2. Comparative Analysis of Tiles Made from Recyclable LDPE Plastic Waste. A. Hardikar, O. Borhade, S. Wagholikar, A. Shivdeo, R. Bhikule. IJERT, Vol. 8 No. 02, 2019.